
Boston Dynamics unveils new four-finger hand for Atlas humanoid robot
Article excerpt
Highlighted: the sentence this signal was extracted from
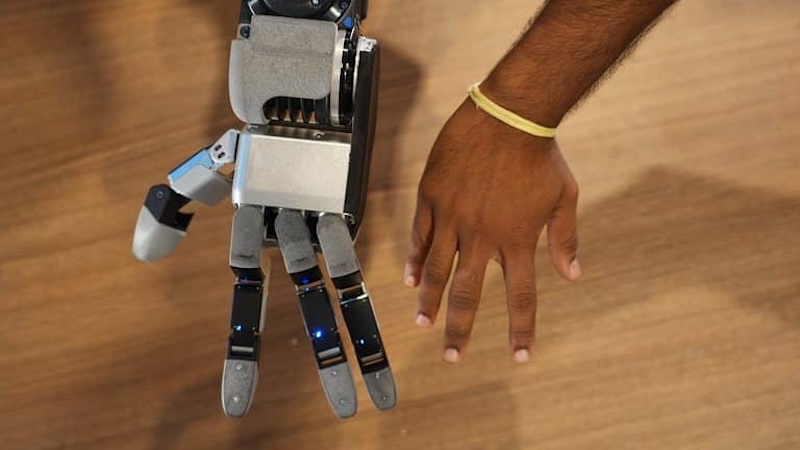
Boston Dynamics has unveiled a new four-finger hand for its Atlas humanoid robot, designed to combine the dexterity needed for complex manipulation and tool use with the strength and durability required for industrial work. The new hand has 13 degrees of freedom (DOF), including a four-DOF opposable thumb, and uses direct actuation together with dense tactile pressure sensors across the fingertips and palm. Boston Dynamics says the design enables Atlas to perform complex manipulation tasks including in-hand object reorientation, pinch and tripodal grasps, recovery from slipping objects, and operation of tools such as drills, power torque drivers, grinders, nail guns and welding torches. The company deliberately chose four fingers rather than attempting to reproduce the five-finger human hand, arguing that eliminating the pinky reduces cost, size, actuator count and potential failure points without significantly reducing functionality. Atlas' previous seven-DOF hands were primarily designed to grasp a wide range of objects. Boston Dynamics says the new generation has been developed to manipulate them. Each of the three fingers has three degrees of freedom, while the opposable thumb has four. The thumb can slide along both the length and width of the other fingers, allowing Atlas to form different pinch and tool-holding configurations. The hand is approximately the size of a...
Keep reading with a free account
The rest of this article, and every signal for Boston Dynamics, is in your free account.